Setting up believable character responses to impact remains one of the most persistent challenges in interactive entertainment. When a player strikes a surface or another entity, the resulting motion must feel grounded and responsive, not floaty or disconnected. The underlying system that governs this behavior traces its roots to early experiments in simulated mass and force, but modern implementations rely on a sophisticated interplay of solver iterations, constraint relaxation, and material properties. Understanding how these elements combine allows developers to craft reactions that serve the narrative without breaking the player’s immersion. The goal is always to bridge the gap between a static model and a living entity that reacts credibly to the unpredictable nature of player input.
Solver Iterations and Performance Trade-offs
The heart of any dynamic simulation lies in the solver’s ability to resolve constraints between bodies within a single time step, ragdoll physics. In practice, increasing the iteration count yields more stable and accurate results, but at a significant cost to frame rate. A typical range spans from as few as ten iterations for preliminary prototypes up to sixty or more for cinematic cutscenes where visual fidelity supersedes real-time demands. Each iteration recalculates positions and velocities, gradually reducing the error between the predicted and actual state of the system. Developers must strike a balance; too few iterations result in jittering or penetration of colliders, while excessive iterations waste precious CPU cycles that could be allocated to rendering or AI logic. The choice often depends on the target hardware, with high-end PCs tolerating heavier solver loads than mobile devices.
Furthermore, the underlying algorithm, whether it employs a sequential impulse approach or a more modern projective dynamics method, affects how quickly the system converges on a solution. Sequential impulse methods process bodies one by one, applying corrections iteratively, which can introduce a subtle accumulation of error over long sequences of motion. Projective dynamics, by contrast, solves for the final state in a single pass, often allowing for higher iteration counts without the same performance penalty. Selecting the right framework involves profiling the specific gameplay scenarios; a fast-paced shooter might prioritize the sequential approach for its predictability, while a slow-paced adventure game could benefit from the stability of projective methods. The ultimate aim is to maintain a consistent illusion of weight without sacrificing the responsiveness that players expect.
Constraint Stiffness and Material Properties
Beyond the numerical solver, the perceived realism hinges on how constraints are defined between the various limbs and the central torso. Stiffness values dictate how much a joint resists deformation when an external force is applied. A high stiffness setting produces a rigid response, suitable for characters wearing heavy armor or those intended to perform athletic maneuvers with minimal give. Conversely, lowering stiffness allows for a more fluid, gelatinous motion, which might be appropriate for fantasy creatures or characters designed to absorb impacts gracefully. Tuning these parameters is rarely a one-size-fits-all endeavor; it requires iterative playtesting to find the sweet spot where the character feels neither too stiff nor too floppy.
Mass distribution also plays a critical role in how a simulated body rotates and translates upon collision. A character with all its mass concentrated in the torso will pivot differently than one with evenly distributed mass across the limbs. Developers often adjust the mass scale of individual bones to simulate the effect of equipment or environmental factors. For instance, attaching a heavy backpack might involve increasing the mass of the spine and shoulder joints while decreasing the effective mass of the legs to simulate the offset center of gravity. These subtle adjustments, though often invisible to the naked eye, fundamentally alter the trajectory and rotation of the character after a collision, contributing significantly to the overall sense of physicality.
Collision Detection and Contact Forces
The moment of impact is governed by the collision detection pipeline, which must identify the precise point of contact between the character’s simplified representation, often a series of capsules or spheres, and the world geometry. Modern engines utilize bounding volume hierarchies to cull distant geometry, ensuring that the expensive raycasts and distance checks are only performed on nearby surfaces. When a contact is registered, the engine calculates a contact normal and impulse magnitude based on the materials’ friction and restitution coefficients. These values determine whether the character slides along a surface or bounces off it, and getting them right is essential for avoiding the “rubber band” effect where a character sticks to walls or floors.
Additionally, the duration of the contact manifold influences how forces are applied over time. A persistent contact, such as a character leaning against a wall, requires different handling than a brief, glancing blow. Engineers often implement contact damping to gradually reduce the impulse as the character attempts to move into the obstacle, preventing the jarring snaps that can occur if the physics engine simply reverses velocity instantaneously. This gradual decay mimics the way real-world objects deform and absorb energy, lending a layer of sophistication to the interaction that players subconsciously appreciate, even if they cannot articulate the specific physics at play.
Sleep States and Energy Conservation
To prevent simulations from spiraling out of control due to accumulated floating-point errors, physics engines employ “sleep” states for bodies that have come to rest. When a character ragdoll comes to a stop, the system evaluates the total kinetic energy against a defined threshold. If the energy falls below this limit, the individual components are marked as asleep, effectively freezing them in place to save computational resources. Waking a sleeping body requires re-applying a sufficient external force, which can sometimes result in a sudden “pop” back to life if the transition is not handled smoothly. Managing these transitions is vital for maintaining a seamless experience, particularly in scenes where multiple characters might interact simultaneously.
Energy conservation settings also dictate how much velocity is retained after a collision. In some scenarios, developers desire a “heavy” feel where the character retains momentum, while in others, a “light” feel where energy is dissipated quickly is preferred. This is often controlled by a coefficient of restitution, which ranges from zero (perfectly inelastic, no bounce) to one (perfectly elastic, maximum bounce). Tweaking this value allows for the differentiation between, say, a fleshy character who absorbs impact versus a metallic robot who might ring like a bell. The interplay between sleep thresholds and restitution coefficients is a delicate balancing act; too aggressive energy loss and the character feels weightless, too little and the simulation becomes unstable.
Authoring Tools and Visual Debugging
For artists and technical designers, the abstract nature of physics parameters can be daunting without proper visualization tools. Many engines provide debug draw modes that render the collision shapes, constraint lines, and velocity vectors in real-time. This visual feedback is indispensable when tweaking stiffness or mass, as it allows the developer to see exactly which joint is failing or where penetration is occurring. Beyond the built-in tools, third-party authoring plugins often offer graph-based interfaces where parameters can be keyframed over time, enabling artists to craft specific reaction animations that blend seamlessly with procedural physics. This hybrid approach, combining authorial control with runtime simulation, is becoming the industry standard for high-quality character responses.
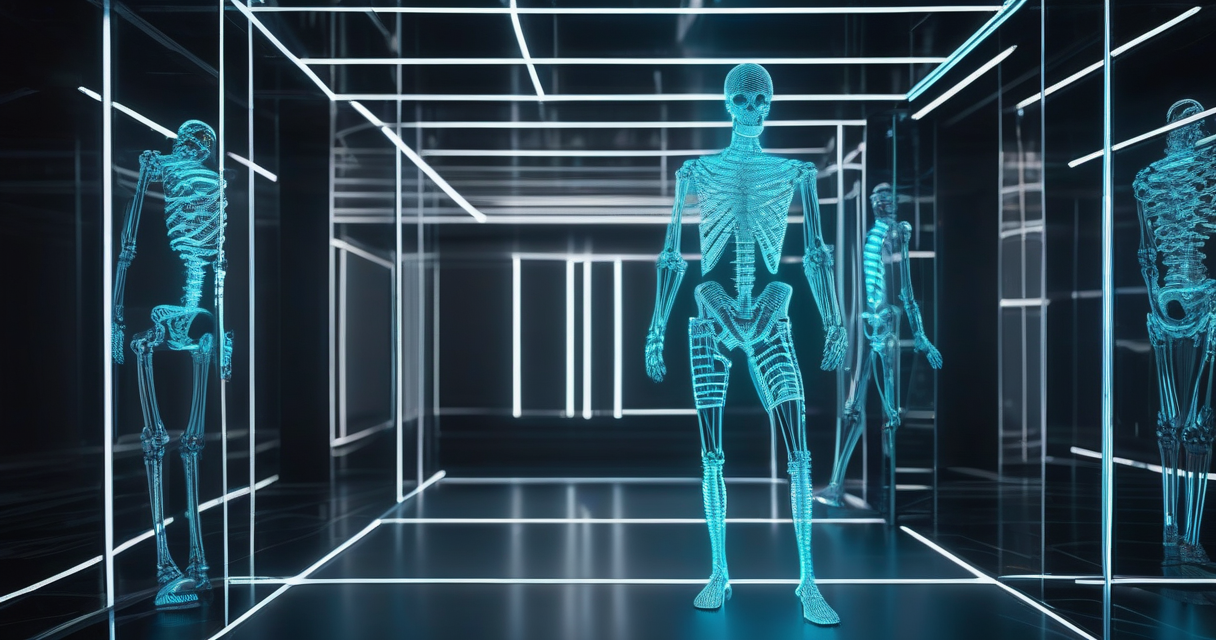
Moreover, the integration of machine learning techniques is beginning to emerge as a way to optimize these setups. By training models on hours of recorded motion capture data, developers can predict the most probable response to a given impact, effectively reducing the search space for acceptable physics parameters. While this technology is still in its infancy for real-time applications, it promises a future where physics settings are auto-tuned to the specific animatic style of a game. Until then, the artist’s eye remains the most reliable instrument, and the iterative cycle of adjust, test, and refine remains the cornerstone of achieving that elusive perfect collision response.
I’ve been playing video games since I was a kid, and that passion naturally led me to explore how they’re made. I love diving into game design concepts and sharing insights with fellow enthusiasts. When I’m not testing new titles, I’m tinkering with Unity and learning new programming tricks.